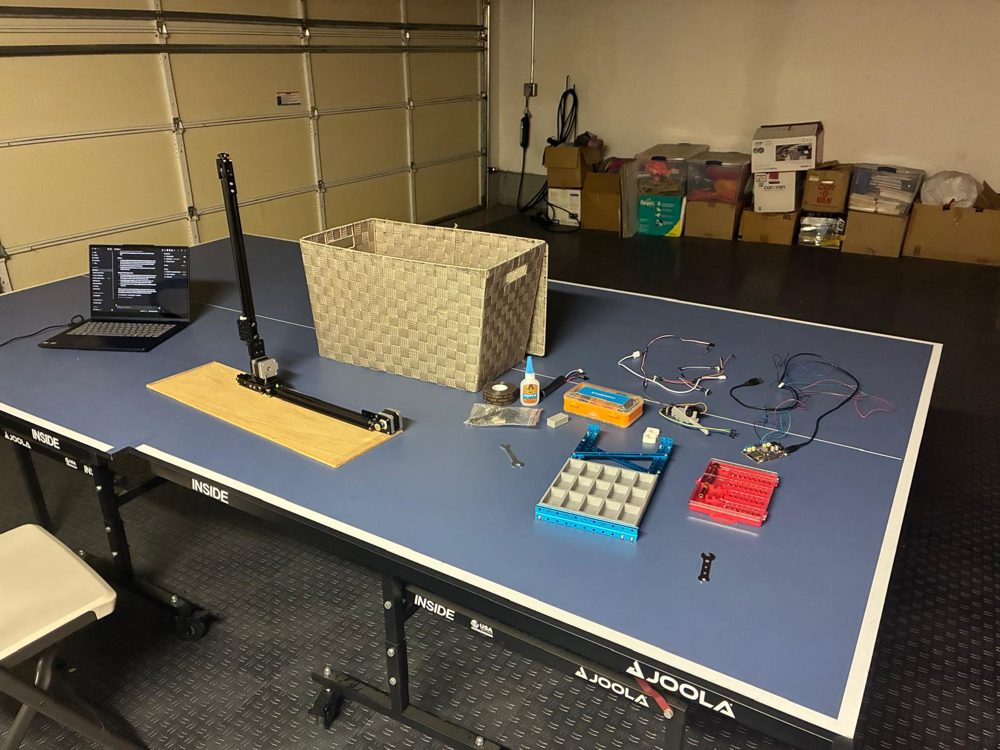
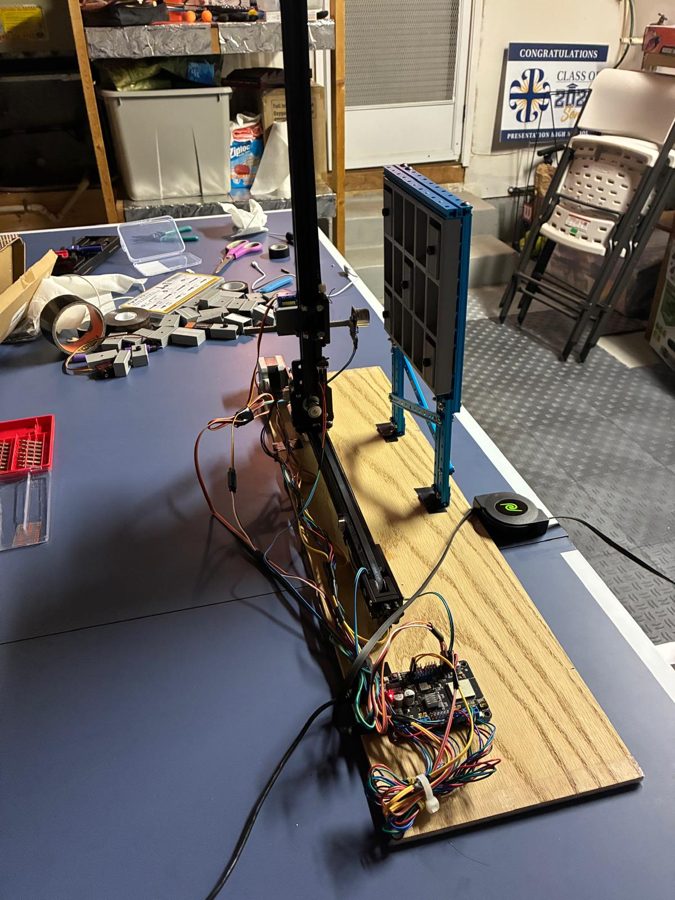
Ask for it, and it's in your hand.
Storage assumes you can reach, see, search and remember. Index doesn't. Ask for what you need by voice or from your phone. A 3-axis robot pulls out the exact tray, brings it to one spot within reach, and puts it back when you're done.
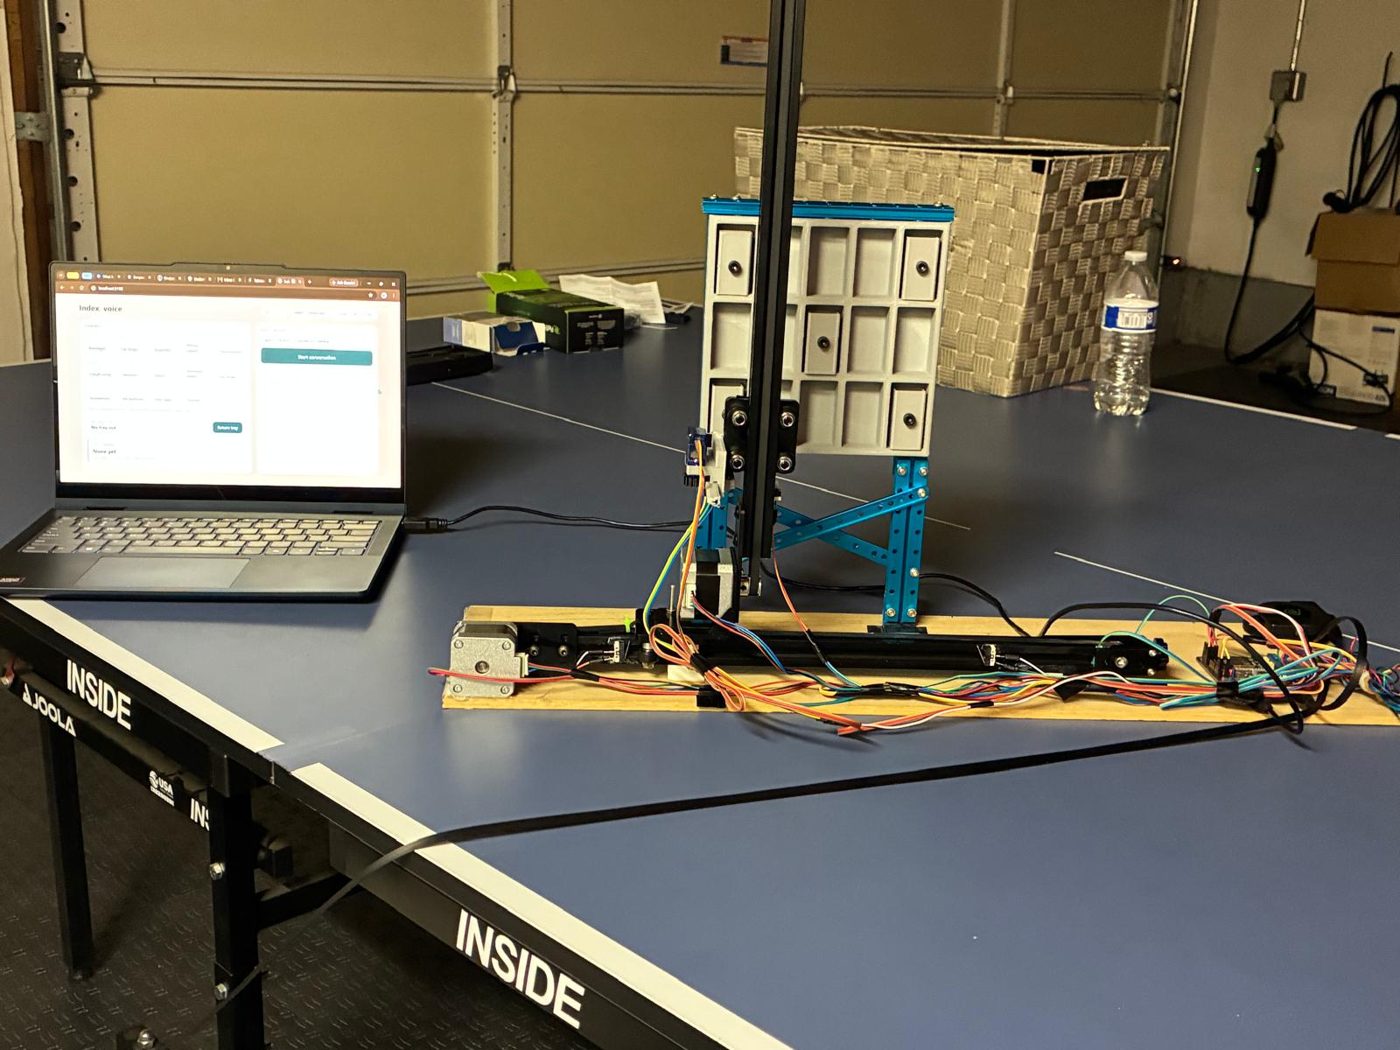
This simulator runs the same logic as the real robot. Ask in plain words or tap a compartment. It sends GO n, waits for ACK n, fetches the tray, and puts it back.
Simulation for the web. On the real robot, an ElevenLabs voice agent does the understanding, with the same rules: it only offers what's in stock, it never gives medical advice, and it moves only after you say yes. The robot must reply ACK n for the exact compartment, or the request is rejected.
Everything runs on one Maker-ESP32 board, which has two built-in H-bridge stepper drivers. Click any part to see its pins and its job.
X horizontal · stepper + GT2 belt on a linear rail · 5 steps/mm
Z vertical · stepper + GT2 belt on a linear rail · up is positive
Y depth · servo rack & pinion · 175° retracted, lower = extended
There are two ways in, by voice over USB or by phone over Wi-Fi. Both end at the same firmware commands. Click a block to see what it does.