Voice-controlled robotic cabinet

Index.

Ask for it, and it's in your hand.

Storage assumes you can reach, see, search and remember. Index doesn't. Ask for what you need by voice or from your phone. A 3-axis robot pulls out the exact tray, brings it to one spot within reach, and puts it back when you're done.
The Index robot: a vertical rail and rack in front of a 15-compartment cabinet, with the control page on a laptop
15compartments (3 × 5)
3axes: X, Z belts + Y rack
0.2 mmpositioning step
1ESP32 runs everything
0apps or internet needed
≈ $300in parts
Interactive

Try Index

This simulator runs the same logic as the real robot. Ask in plain words or tap a compartment. It sends GO n, waits for ACK n, fetches the tray, and puts it back.

Front view · live

X rail (belt + stepper) DELIVERY SPOT Z rail

Side view · Y rack + electromagnet

cabinet slot servo

Ask Index

Hi, I'm Index. What can I get for you?
No tray out

Or tap a compartment

USB serial log

Simulation for the web. On the real robot, an ElevenLabs voice agent does the understanding, with the same rules: it only offers what's in stock, it never gives medical advice, and it moves only after you say yes. The robot must reply ACK n for the exact compartment, or the request is rejected.

Hardware

Wiring diagram

Everything runs on one Maker-ESP32 board, which has two built-in H-bridge stepper drivers. Click any part to see its pins and its job.

Selected part

Axis convention

X horizontal · stepper + GT2 belt on a linear rail · 5 steps/mm

Z vertical · stepper + GT2 belt on a linear rail · up is positive

Y depth · servo rack & pinion · 175° retracted, lower = extended

Software

From words to motion

There are two ways in, by voice over USB or by phone over Wi-Fi. Both end at the same firmware commands. Click a block to see what it does.

Selected block

A retrieval, step by step (firmware sequencer)

1 · HomeRetract the rack, then find Z-min and X-min with the limit switches. Skipped if already homed.
2 · MoveX and Z travel together to the taught compartment position.
3 · GrabThe rack extends to the reach angle, the magnet turns on, and after a 400 ms settle the tray is pulled out.
4 · DeliverRise to the delivery height, move across, and set the tray on top. The magnet keeps holding.
5 · ReturnGo in 3 mm higher, push in, magnet off, slide up 10 mm, retract, park, then release the motors.
Build log

From a rail on a board to a working robot

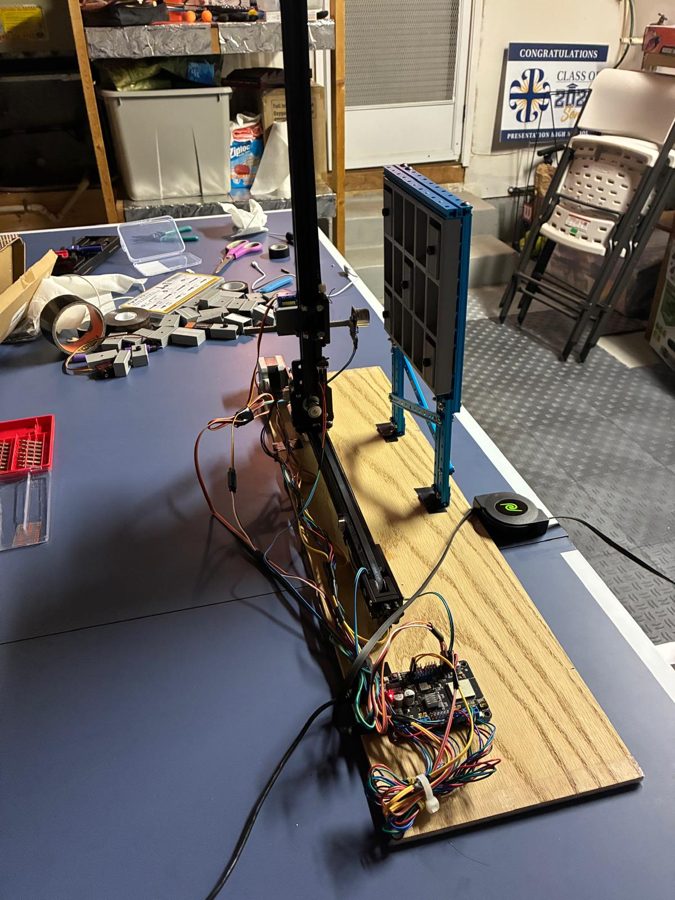
Early build: a single rail on a wooden board with parts laid out
Day one: the X rail, the Z rail and a pile of parts.
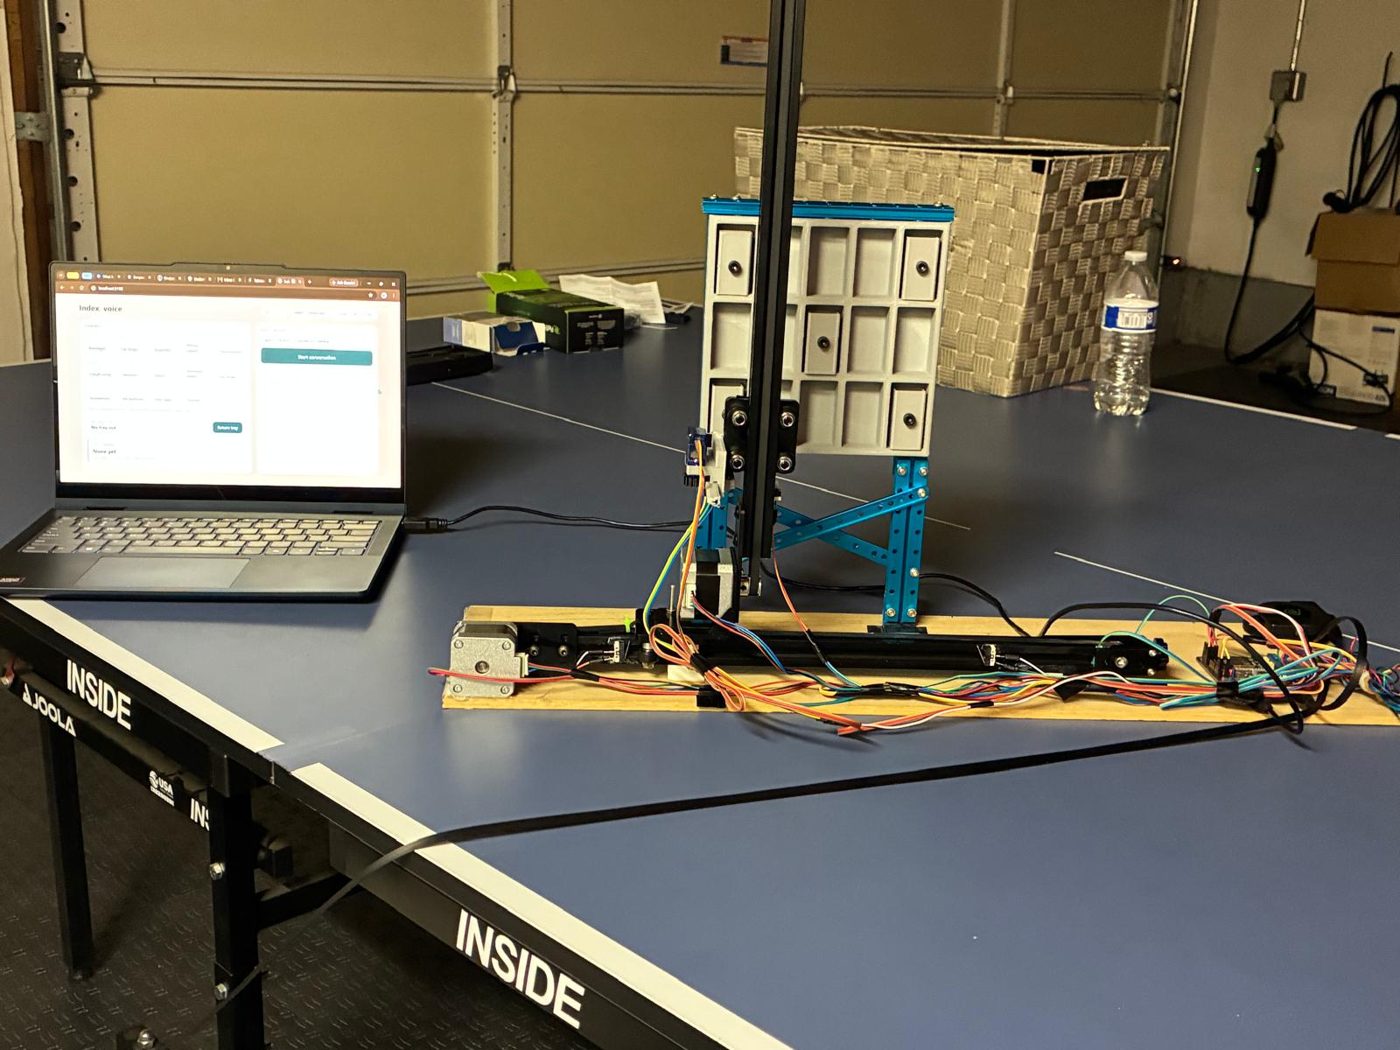
The gantry with the 15-compartment cabinet mounted beside it
The gantry, the cabinet and the wiring come together.
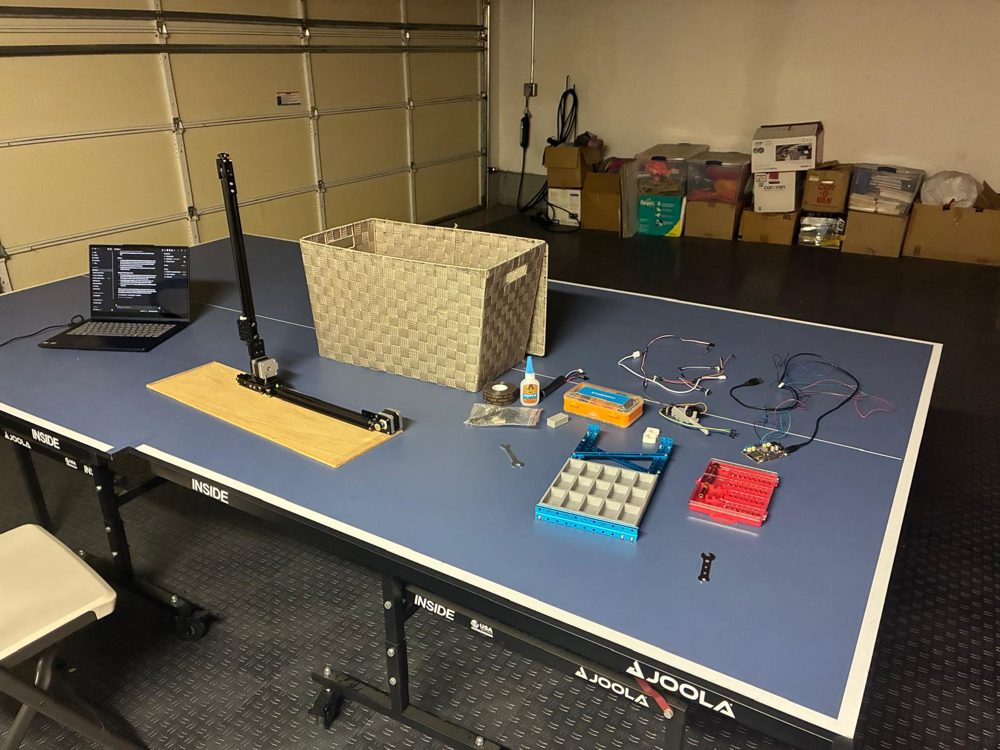
The finished Index robot with its control page
The finished robot with its control page.

Hardest problems solved

Trays catchingGoing back in, trays hit the opening. Fix: return 3 mm higher than the pickup height.
Trays dragged outAfter the magnet turned off, friction pulled the tray back out. Fix: slide up 10 mm off the washer before retracting.
Switch bounceLimit switches bounced when released. Fix: debouncing plus a re-arm distance.
Battery in minutesThe drivers held full current while idle. Fix: release the motors when idle, and use a wall supply.
Rail on a railBalancing a long Z rail and the Y rack on the X carriage without wobble.